Agribot - Agricultural robot
Agribot is an agricultural robotics project designed for remote manual or automatic control. It explores how sensors and actuators could help agriculture adapt to climate change, for example by detecting weeds and applying targeted treatments.
My contribution
- Designed and developed the user interface, excluding the maps.
- Implemented weed detection.
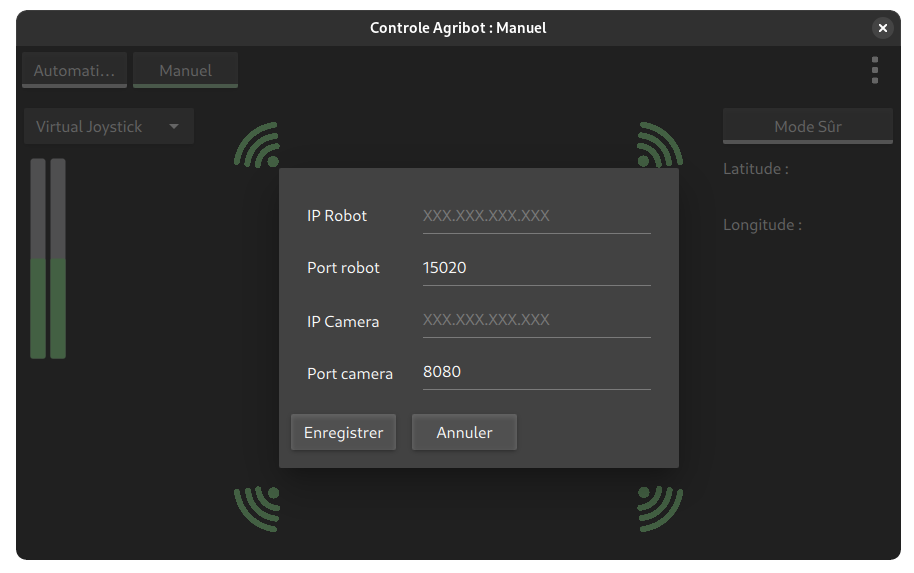
- Implemented communication between the application and the robot.
Planned capabilities (partially implemented)
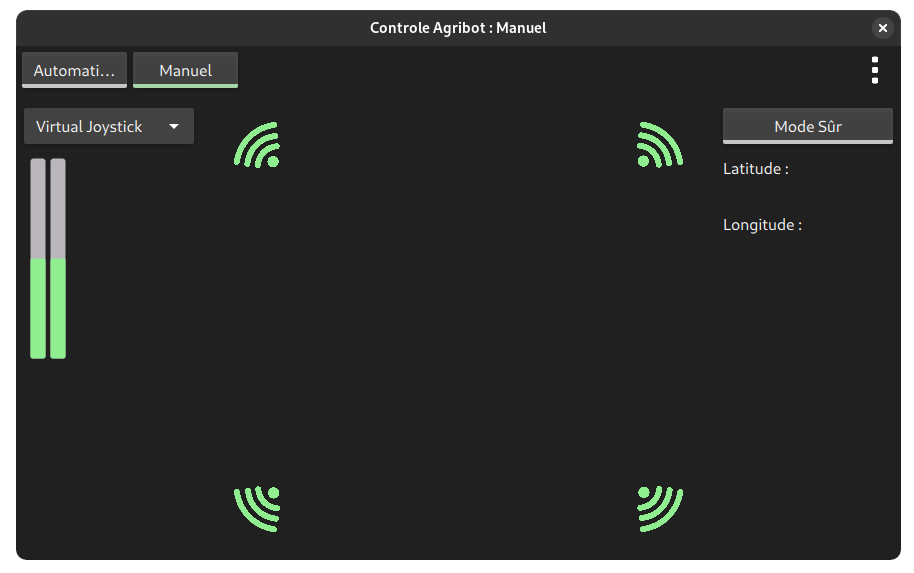
- Control the robot manually over Wi-Fi
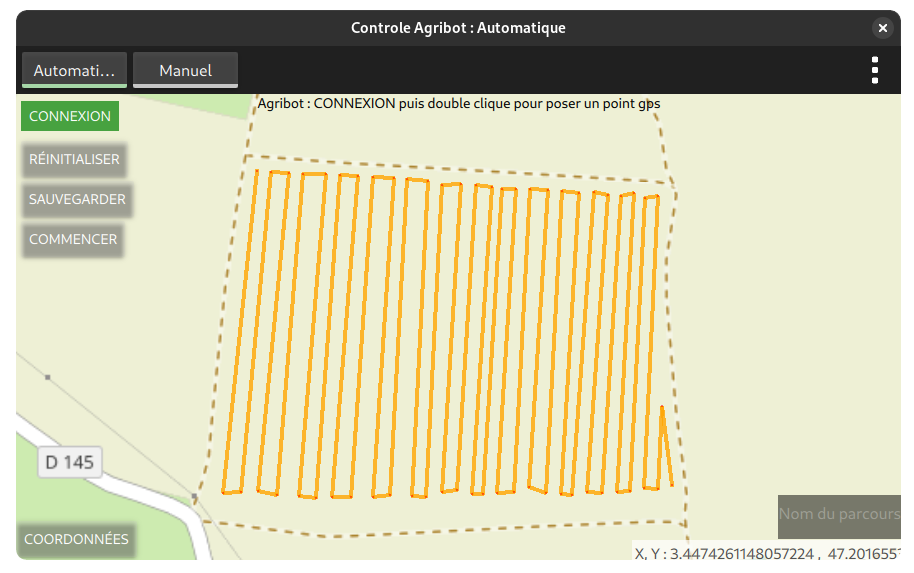
- Follow a route defined by GPS waypoints and use AI to identify and remove weeds
- Save GPS routes in a database
- Trigger weed treatment manually
- Use a virtual joystick controlled from the keyboard
Screenshots
Photos
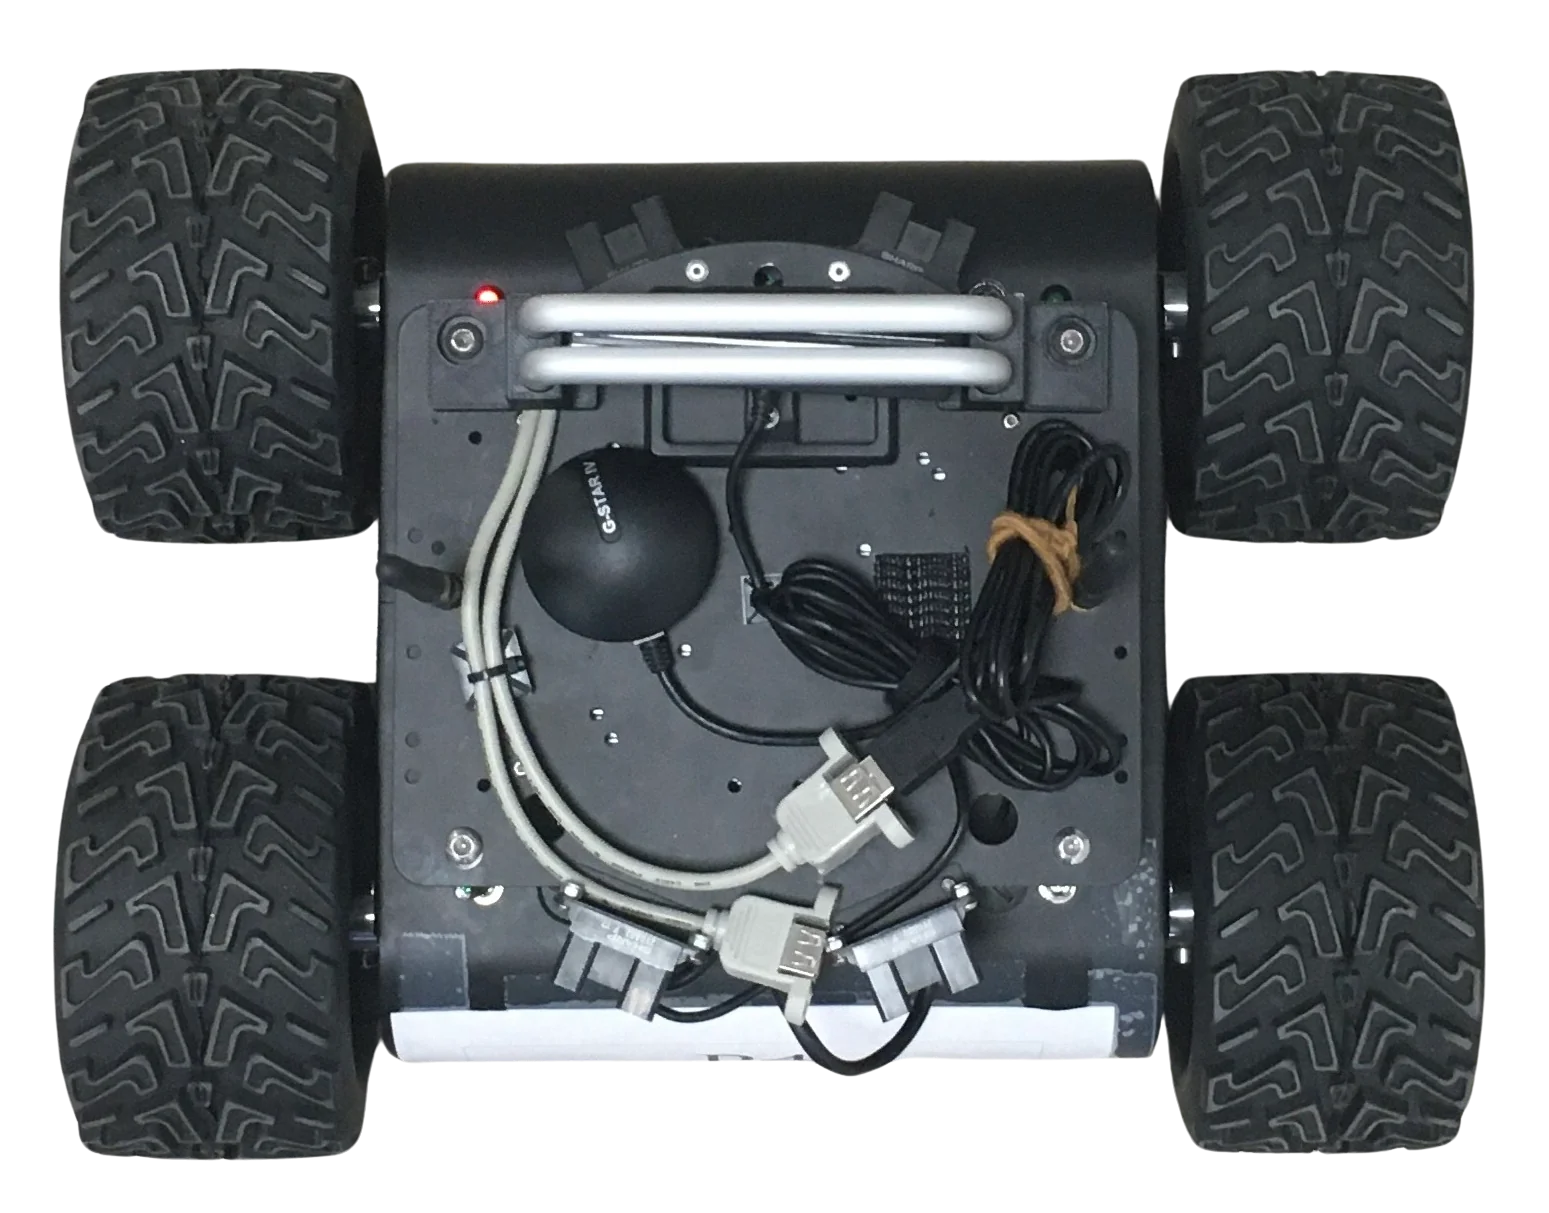
Acknowledgements
Thanks to my teachers for proposing this project.
Thanks to Alex Spataru for the QJoystick library.
Thanks to my teammates for working on this project with me.
Thanks to WifiBot for their robot.